11 results · ↑↓ select · Enter open · Esc close

A WORK IN PROGRESS. LIKE MOST GOOD THINGS.

EDISON, NJ / EST. 2023 ON GITHUB

Hey, I’m Arya.

I make
code move.

Sometimes it moves a robot. Sometimes it makes a workflow a little less painful. I build across hardware, software, and the space in between.

ARYA VORA / ARYAVORA621 / FRINKLYY

Move your pointer. I’m curious. Procedural 3D model, built in code

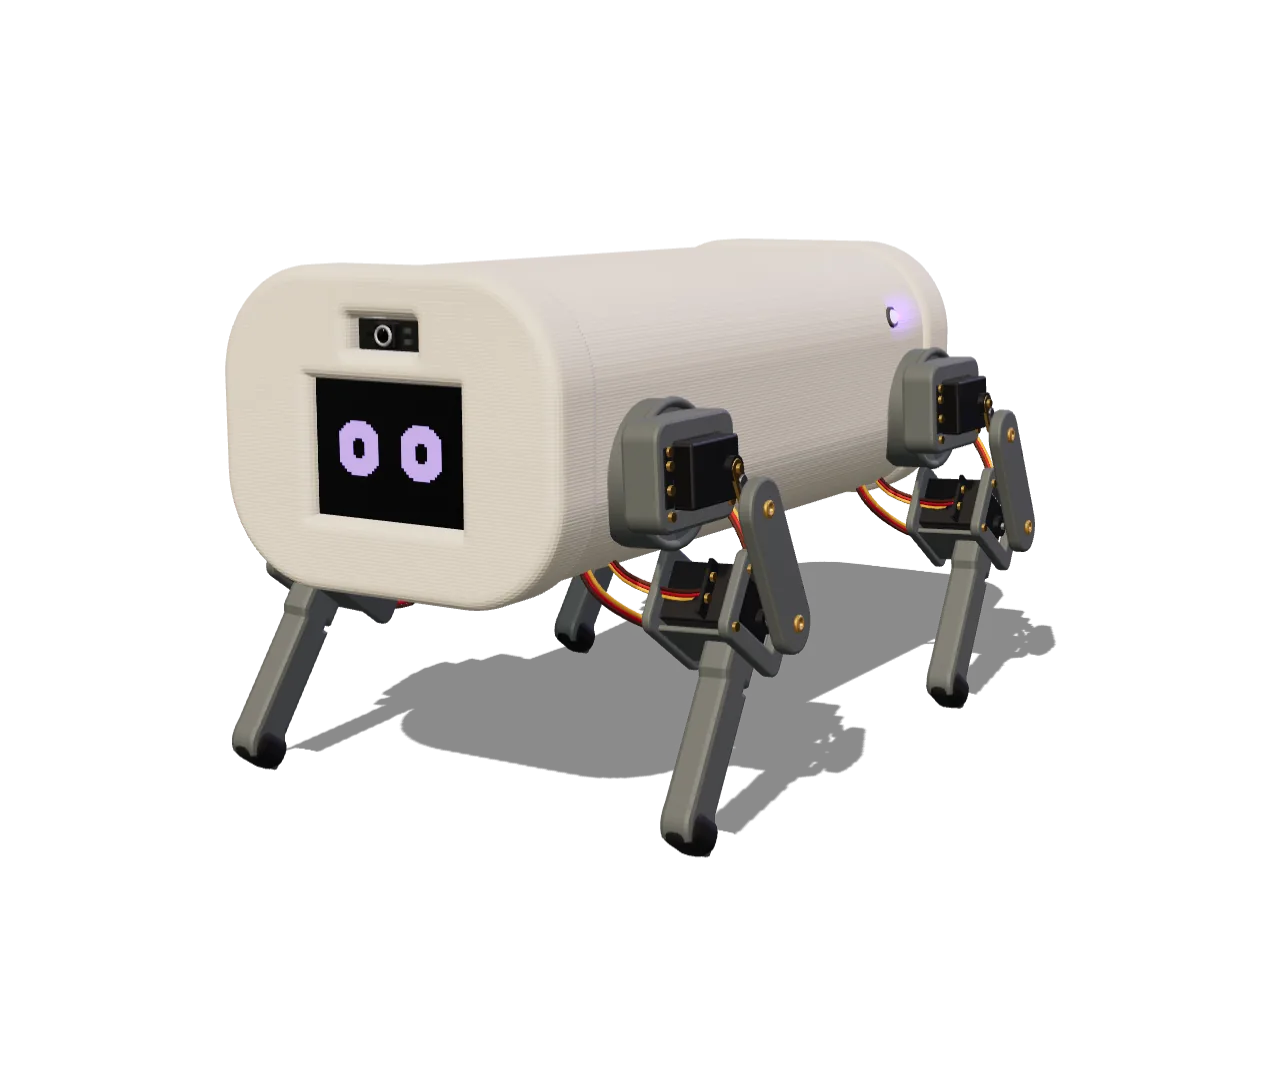
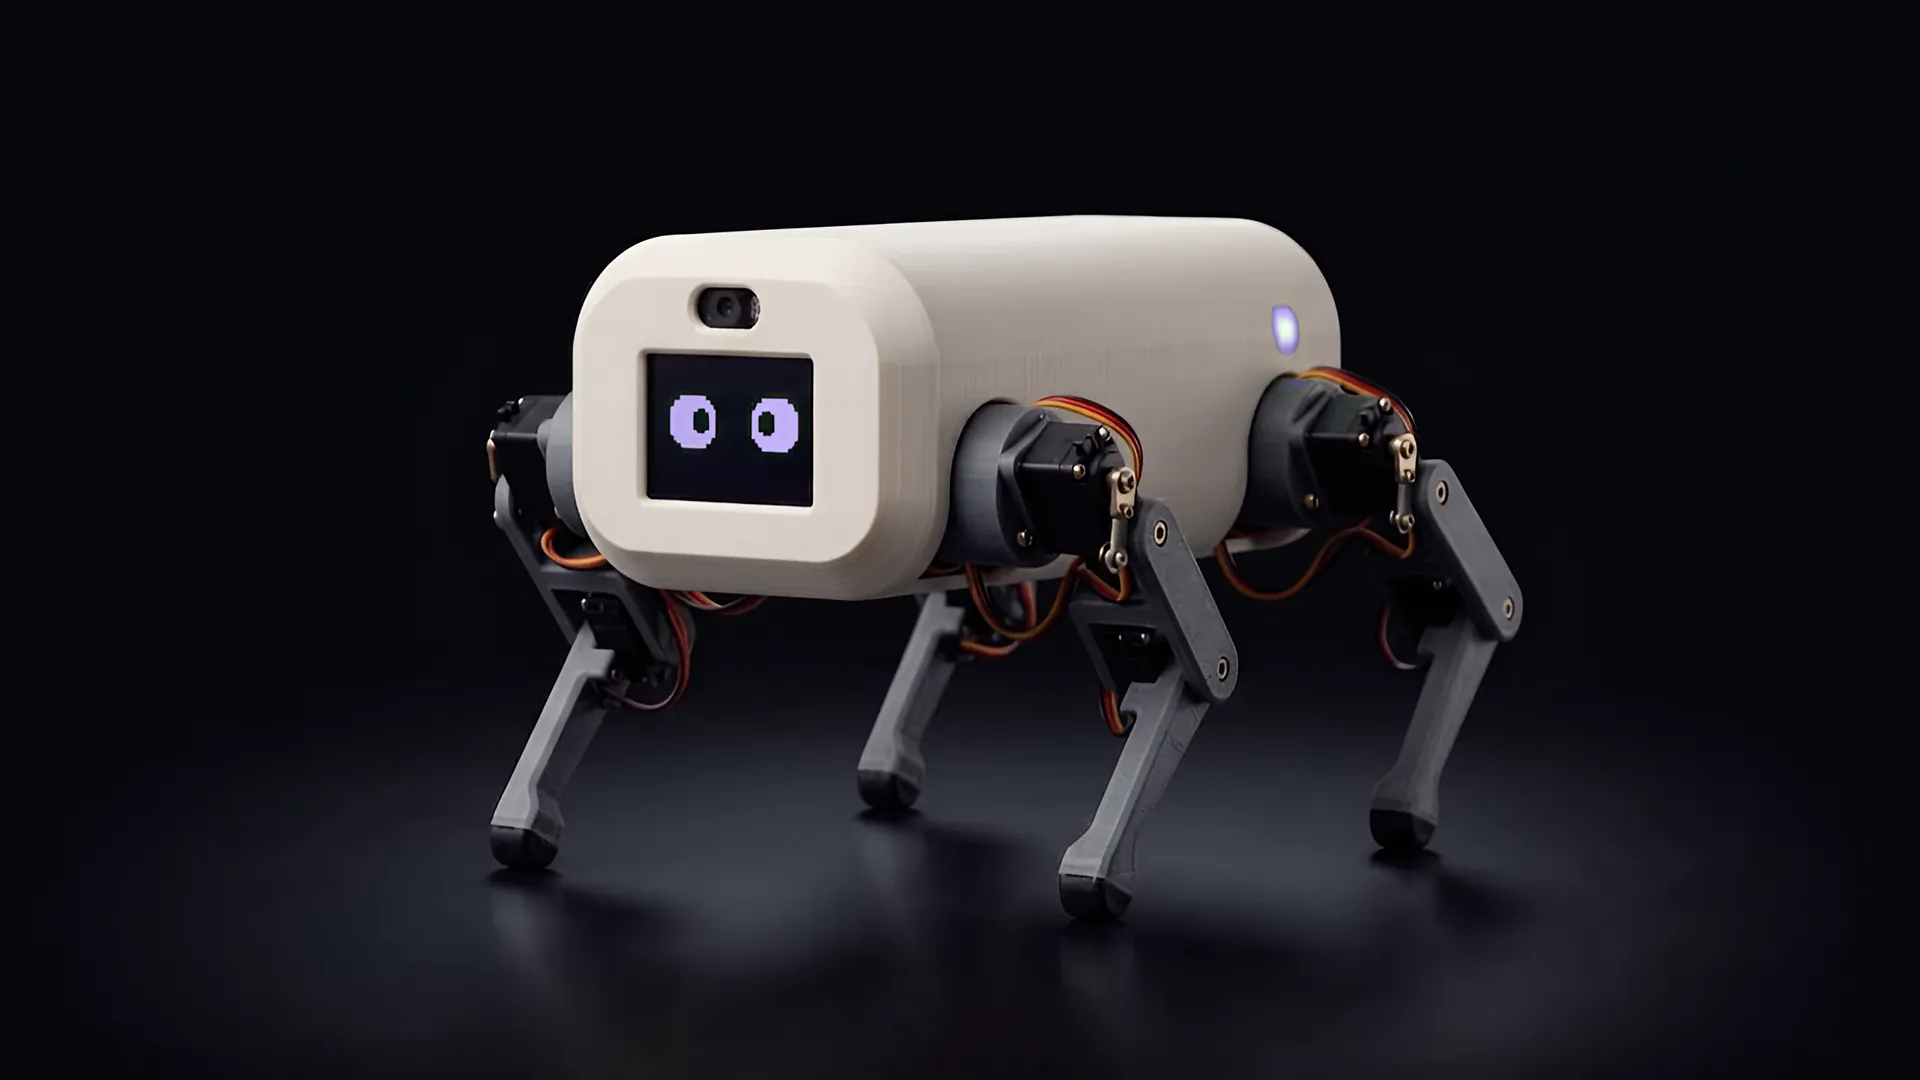
Concept render of roboPet, a small four-legged robot with an off-white shell and an OLED face showing two violet eyes.

FEATURED BUILD / 01

Meet roboPet.

A four-legged companion, built to learn mechatronics end to end.

  1. LOCOMOTION

    Twelve servos. Three joints a leg.

    Hip, upper leg, lower leg. MG996R servos on a printed PLA frame, driven at 50 Hz by a non-blocking state machine.

  2. ARCHITECTURE

    Two brains, on purpose.

    A Raspberry Pi Pico runs the real-time loop: sense, think, act. A Pi Zero 2W handles camera, audio, RC and, eventually, the agent.

  3. POWER

    Two rails. No brownouts.

    One buck converter feeds the servos at about 7.2 V, another holds the logic at 5 V. Gait current spikes never reach the boards.

Hardware in progress.
Every decision documented.

Read the build log

ROBOPET / EXPLODED VIEW

Every part,
on purpose.

A procedural Three.js reconstruction, built in code from the concept render. Pick a part to see what it does.

INTERNALS ARE INFERRED, NOT MEASURED

Seven subsystems

Structure, face, perception, control, power and locomotion. Each one is a decision documented in the build log.

01 / SELECTED WORK

Ideas don’t build
themselves.

From things that walk to tools that ship.
A few projects worth opening up.

6 selected projects shown

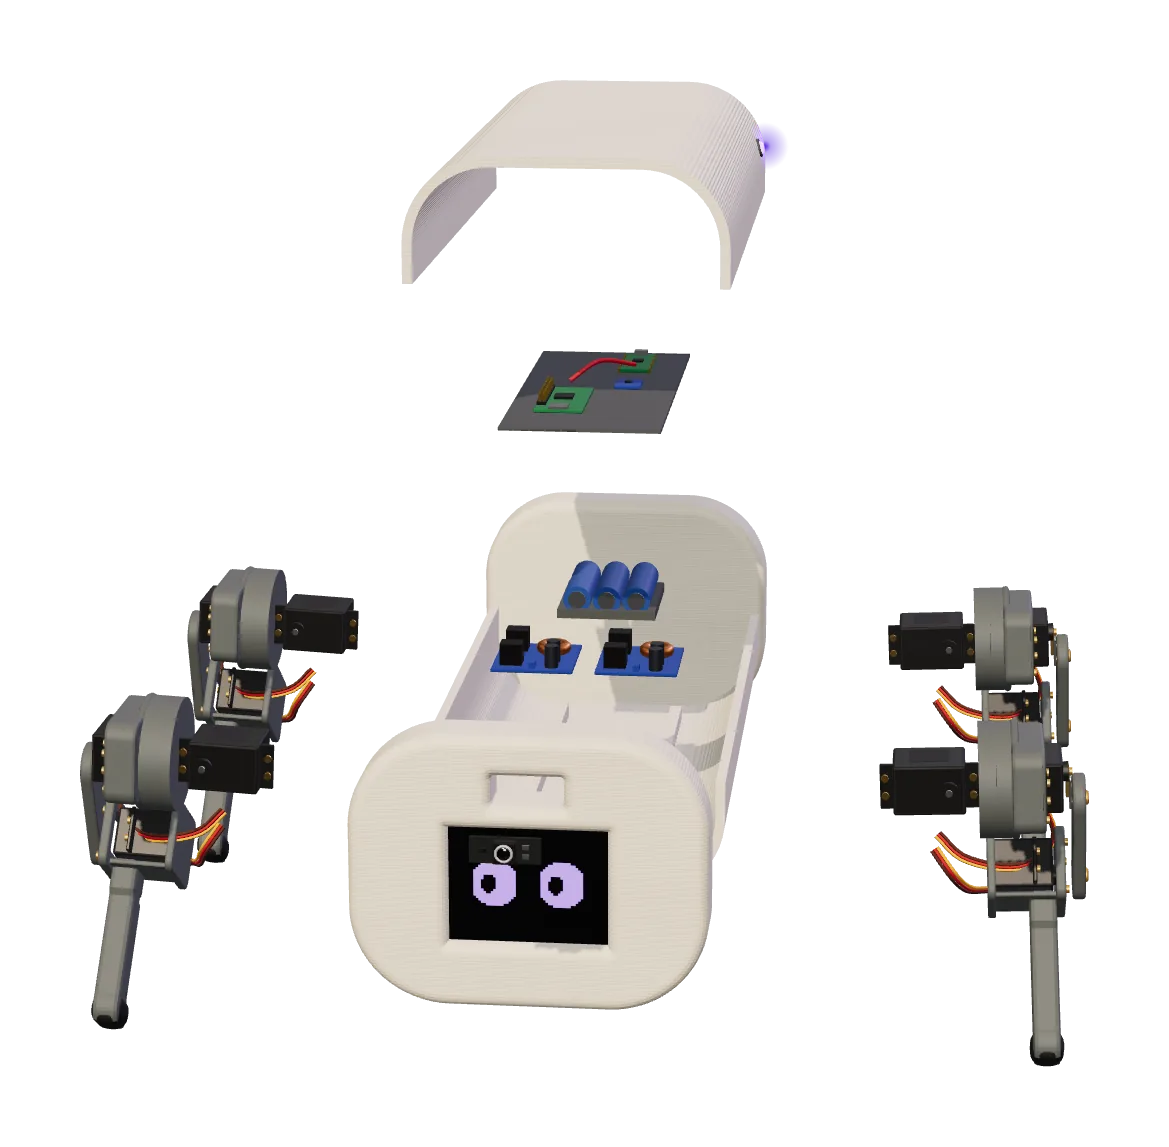
Exploded view of the roboPet model: shell lifted off, control boards and battery pack above the chassis, four servo legs pulled out to the sides.

Procedural model, exploded

01RoboticsHardware in progress

roboPet

A little robot. A lot to learn.

A four-legged companion built to learn mechatronics from the ground up. Custom printed parts, servo control, and a two-board architecture.

Built with MicroPython · Raspberry Pi · CAD

Under the hood

The current work is hardware bring-up and locomotion: a Raspberry Pi Pico for real-time control, with a Pi Zero 2W planned as the higher-level brain. Learned locomotion and onboard AI are goals, not finished features.

Repository

Illustration, not a screenshot

02SystemsNative application

notchTerm

Your agents, at a glance.

A macOS notch companion that brings Claude and Codex terminal sessions into a compact SwiftUI overlay.

Built with Swift · SwiftUI · macOS

Under the hood

The overlay expands on hover, previews terminal output, and routes messages to the selected session. Terminal automation requires macOS permissions. This portfolio preview is an illustration, not a running macOS app.

Repository
  1. 03

    OpenUltraCode

    Parallel agents. Explicit boundaries.

    A local CLI for parallel coding agents, adaptive model routing, and inspectable run artifacts. An organization repository in my GitHub workbench.

    AIEarly CLI foundationTypeScript · Node.js · CLI

    Under the hood

    An early TypeScript CLI foundation with deterministic planning, model-tier routing, isolated edit worktrees, cost accounting, and opt-in patch application. The interactive lab below illustrates orchestration; it does not execute the CLI or call a model.

    Repository
  2. 04

    TeamStat Insights

    Make the next match count.

    An FTC scouting app made by Team 23786 MakEMinds. Competition software for the people behind the robot.

    RoboticsTeam softwareTypeScript · Next.js · FTC

    Under the hood

    The repository identifies this as an FTC scouting app by Team 23786. The sketch shows match phases only, not actual team results or competition statistics.

    Repository
  3. 05

    ShipKit

    From prototype to production.

    A production-readiness scanner for AI-built web apps, with security, deployment, and quality findings in one place.

    SystemsWeb applicationNext.js · Supabase · Stripe

    Under the hood

    A Next.js application with Supabase for authentication and data, plus deployment and billing flows. The preview is illustrative and does not scan the visitor’s files or claim a security certification.

    Repository
  4. 06

    Jarvis-Bee / smartAI

    Local intelligence, under construction.

    An offline-first agent system for macOS, pairing a Queen-and-Swarm architecture with an interactive HUD.

    AIExperimentalPython · FastAPI · WebSockets

    Under the hood

    The public roadmap marks the swarm core, tools, WebSocket server, and HUD as implemented. Fine-tuning, self-healing, and several safety features remain roadmap items; they are not presented here as completed capabilities.

    Repository

02 / THE PLAYGROUND

Less scrolling.
More tinkering.

A couple of ideas from my work, made small enough to play with. Everything runs right here in your browser.

EXPERIMENT 01

Find a way through.

Add walls. Run the planner. Watch a shortest route emerge.

S / StartG / Goal× / WallGreen / Route

Tap cells to toggle walls. Arrow keys move between cells.

Browser simulation · Breadth-first search, 4-way movement. Not a live robot controller.

EXPERIMENT 02

One task. A small crew.

Follow a task from planning to verification in a local-agent workflow.

  1. 01

    PlannerWaiting

    Waiting for the previous stage.

  2. 02

    BuilderWaiting

    Waiting for the previous stage.

  3. 03

    ReviewerWaiting

    Waiting for the previous stage.

  4. 04

    VerifierWaiting

    Waiting for the previous stage.

Ready. Choose a task and run the workflow.

Scripted illustration · No AI calls, terminal access, or files uploaded.

Get into the actual code

03 / THE PERSON BEHIND THE COMMITS

A builder.
Still learning.

I’m Arya Vora, based in Edison, New Jersey. Robotics is where my interests come together: code, mechanical design, and seeing what happens when an idea has to work outside a screen.

I captain FTC 23786 MakEMinds and serve on the board of FRC 2554 The Warhawks. Away from the field, I work on companion robots and tools for developers.

Arya VoraALSO AROUND AS FRINKLYY
Follow the work
01 / ROBOTICS & HARDWARE

Make it physical.

FTC and FRC, custom parts, companion robots. The feedback is immediate when a mechanism jams or a servo won’t move.

CADMicroPythonRaspberry PiJava
02 / SOFTWARE & SYSTEMS

Make it useful.

Scouting apps for the team. A notch companion for terminal sessions. Tools that begin with a small, recurring frustration.

TypeScriptNext.jsSwiftUIPython
03 / EXPERIMENTS & OPEN SOURCE

Leave the process visible.

Agent workflows, prototypes, and unfinished ideas. The repos include roadmaps and work in progress, not just the polished parts.

GitHubLocal agentsIteration
THE THROUGH LINE

Curiosity is the starting point.
Making it work is the fun part.

04 / OPEN A CONVERSATION

Got something
worth building?

Robotics, a useful tool, a strange idea.
I’d like to hear about it.

Opens your email app. Nothing is sent by this website.